Homepage
Biography
I am Huailiang Ma, a student in the combined M.S./Ph.D. program at Southeast University, with joint research training at Shanghai Innovation Institute. My research focuses on embodied intelligence and robot learning, particularly world models, vision-language-action (VLA) models, robot data generation, and robotic manipulation.
I received my B.Eng. in Automation from the School of Control Science and Engineering at Shandong University, where I was advised by Prof. Guoteng Zhang. My graduate advisors are Prof. Aiguo Song and Prof. Lifeng Zhu.
Education
- 2024 - Present, Ph.D. Student, Southeast University & Shanghai Innovation Institute
- 2020 - 2024, Bachelor of Engineering in Automation, Shandong University
Research Interests
- Embodied intelligence and robot learning
- World models and Vision-Language-Action (VLA) models
- Imitation learning and robot data generation
- Robotic teleoperation and dexterous manipulation
- Humanoid robot odometry and control
Selected Publications
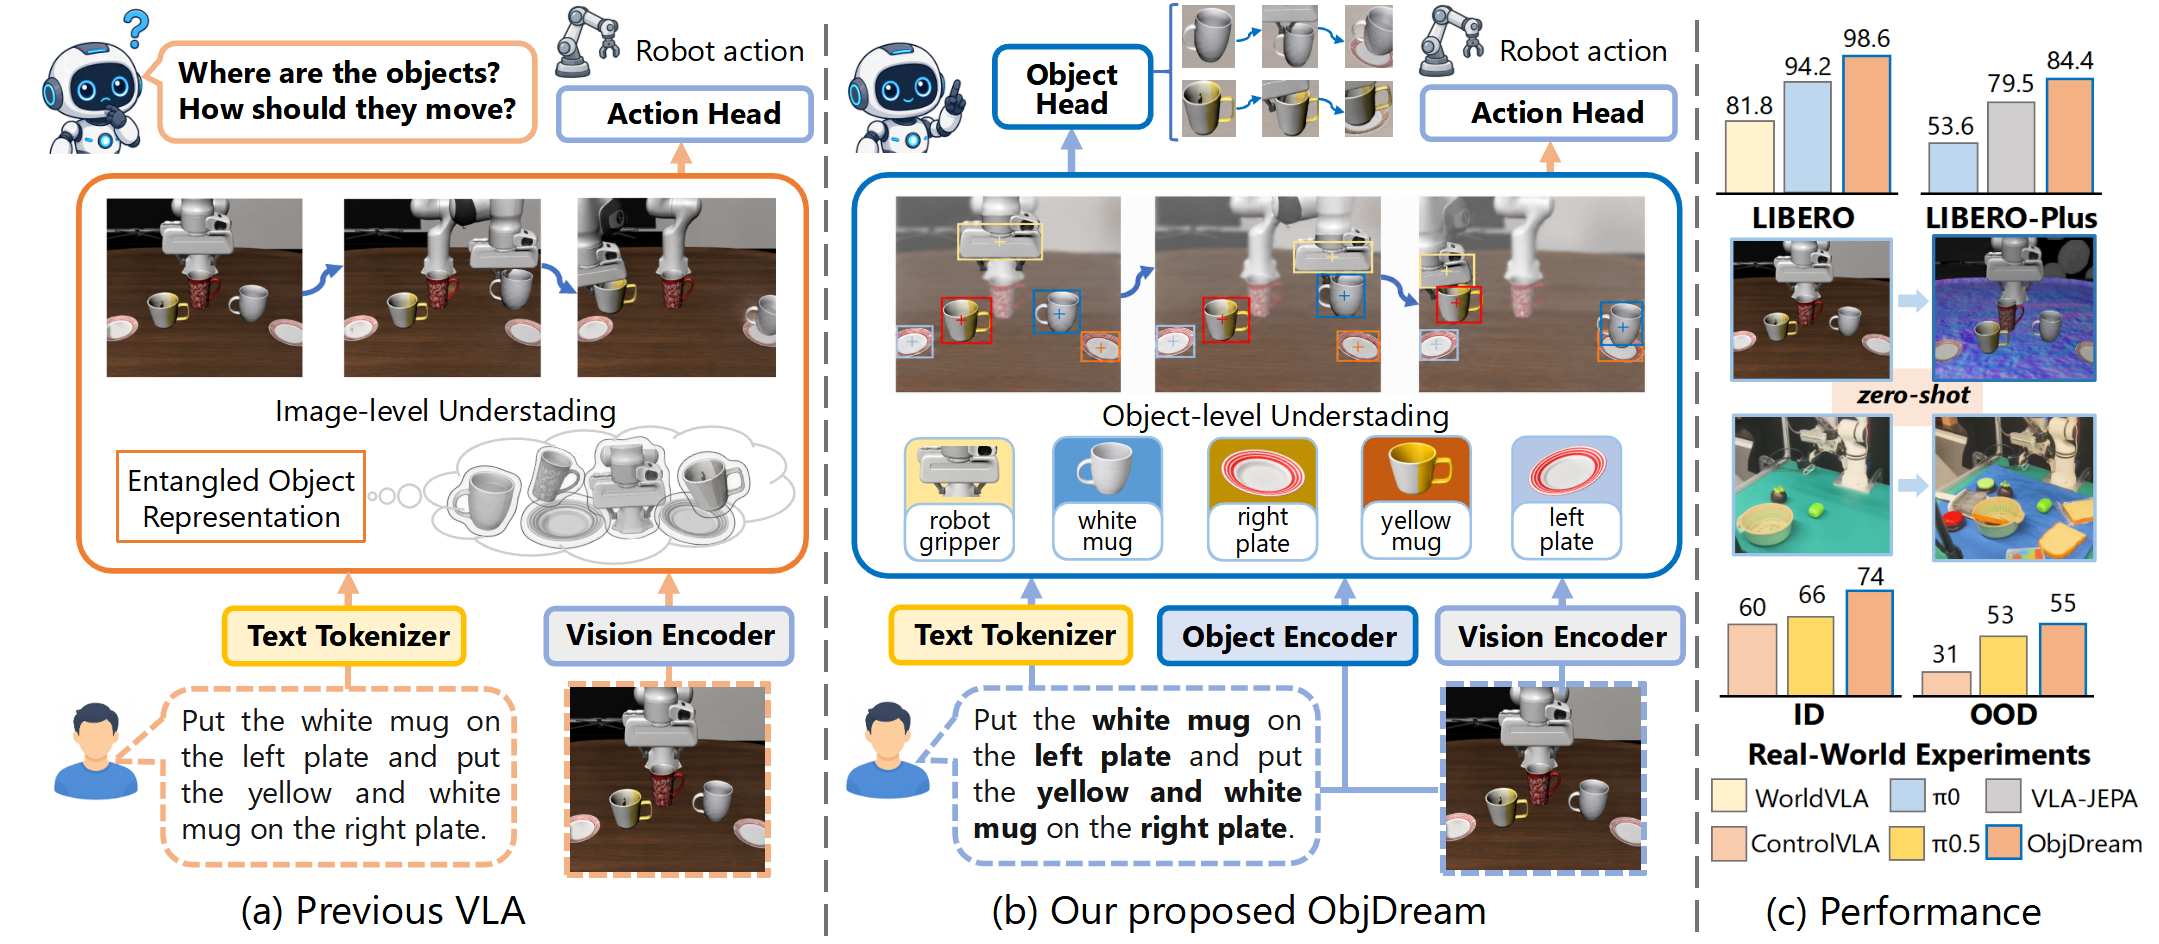
Ma, H., Li, Y., Zhao, Z., Wang, X., Li, M., Guo, X., Zhu, L., Song, A., Lu, C., Sun, J.
ObjDream: Guiding Vision-Language-Action Models with Object-Level Understanding and Future State Prediction.
Under review. Project Page
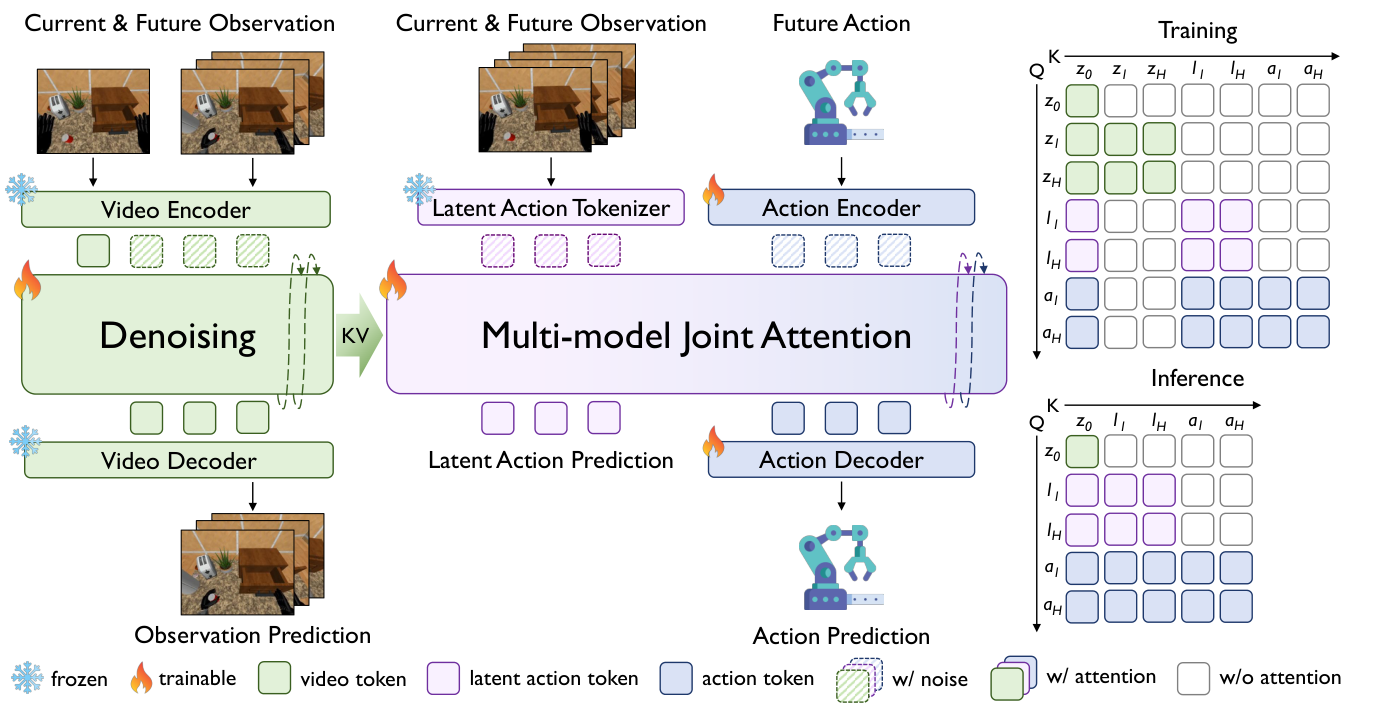
Li, X.*, Zheng, Y.*, Gu, S.*, Ma, H.*, Yu, F., Zheng, Y., et al.
Latent Action as Intention Enables Efficient Future Imagination for World Action Models.
Under review. *Equal contribution.
Anonymous authors.
Compact and Robust Robot Policies.
Under review.
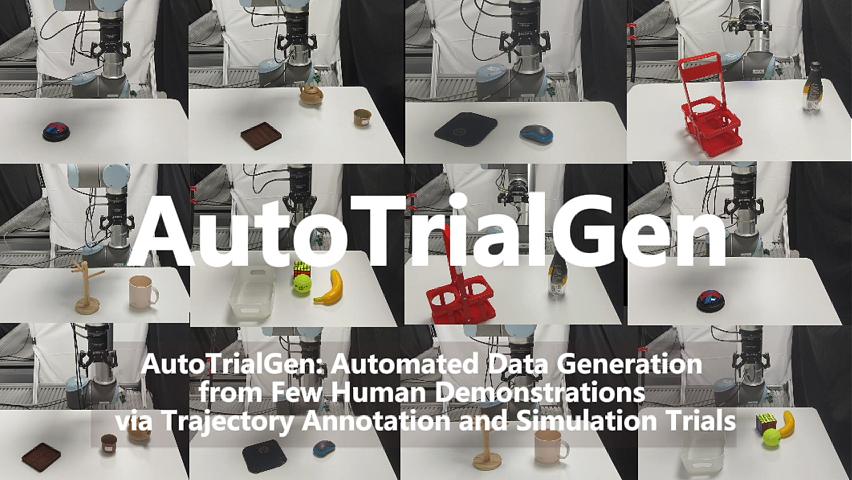
Ma, H., Song, A., He, M., Yan, Y., Li, M., Wei, L., et al.
AutoTrialGen: Automated Data Generation from Few Human Demonstrations via Trajectory Annotation and Simulation Trials.
IEEE Robotics and Automation Letters (RA-L), 2026. Accepted.
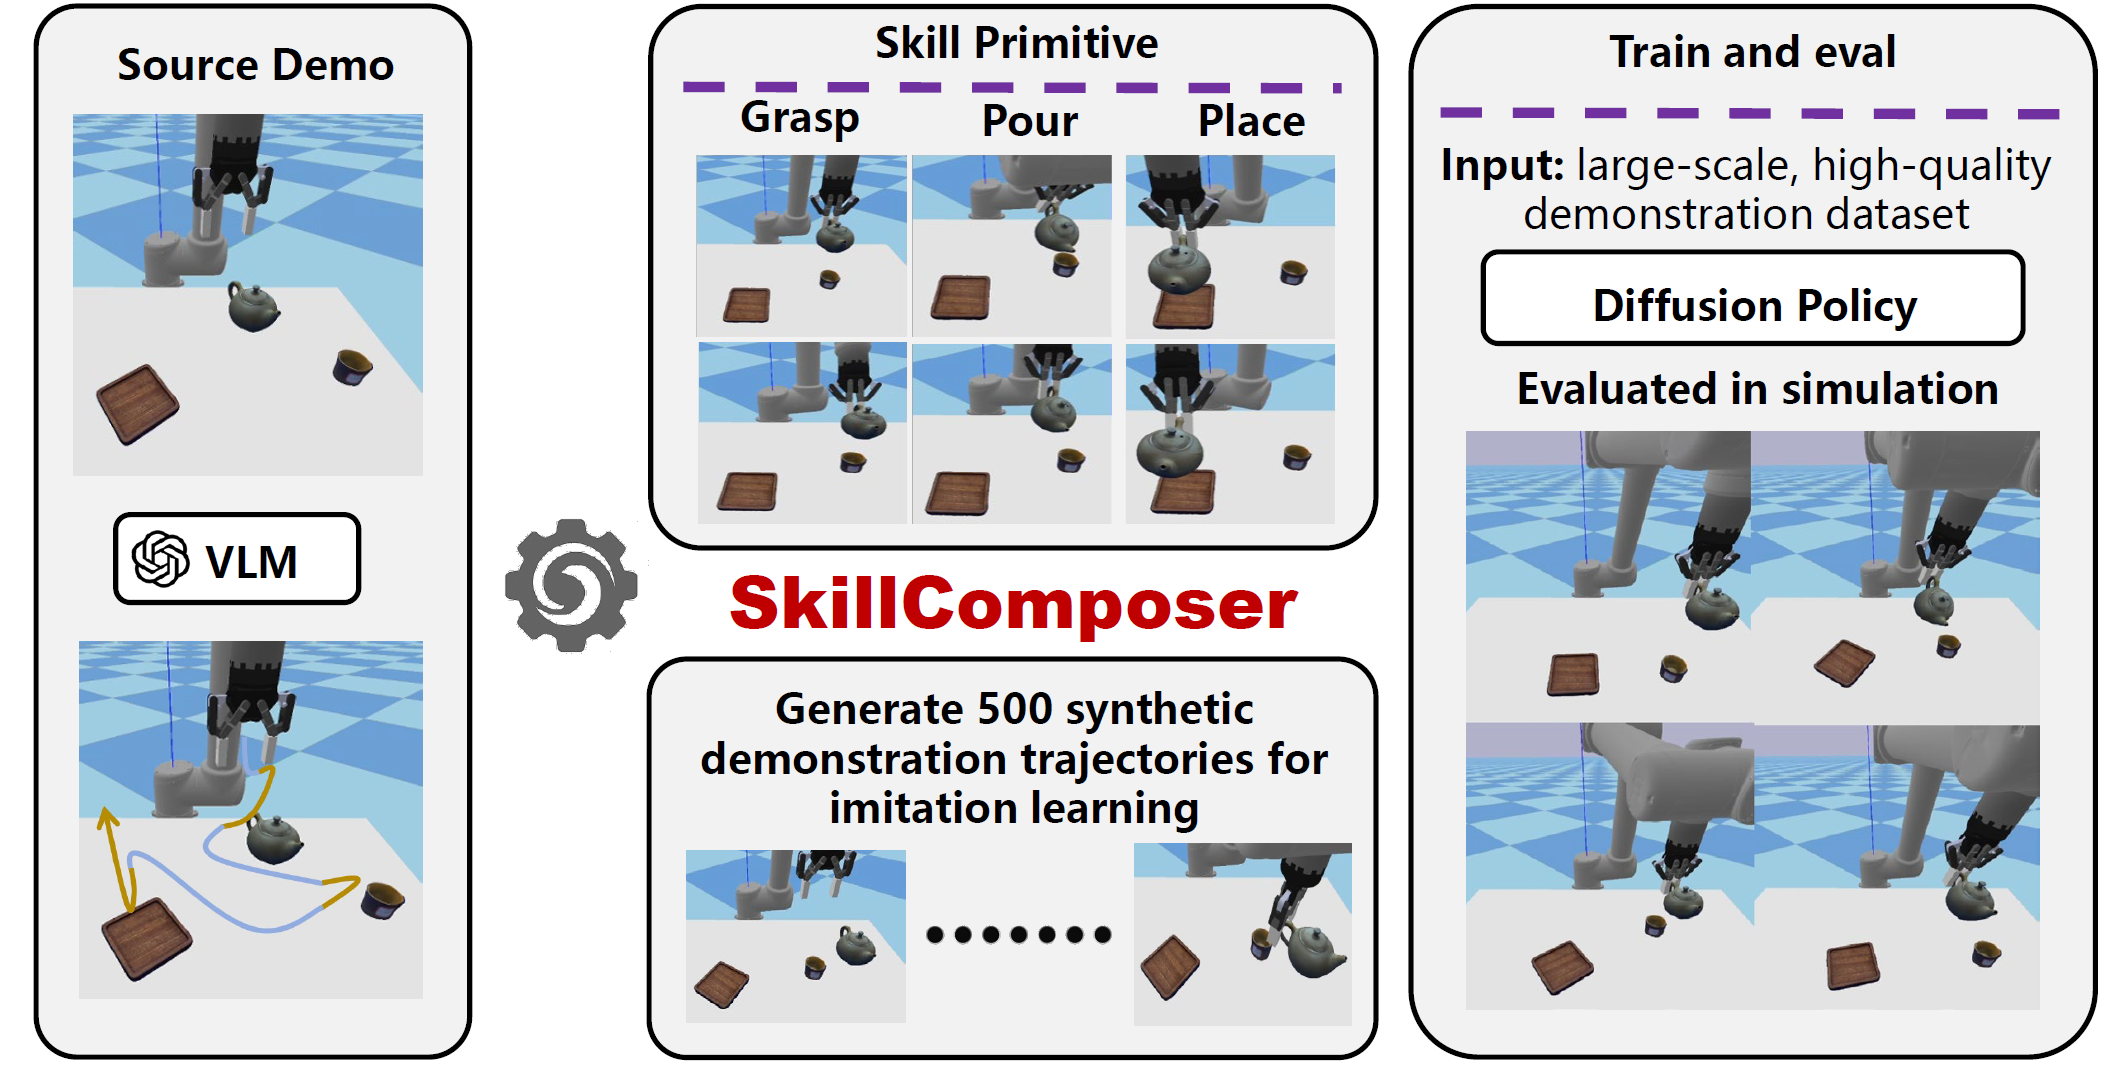
Ma, H., Song, A., Xu, B., et al.
SkillComposer: Automated Segmentation and Robot Skill Composition for Scalable Data Generation.
International Conference on Bio-inspired System and Robotics (ICBSR 2026), 2026. Accepted.
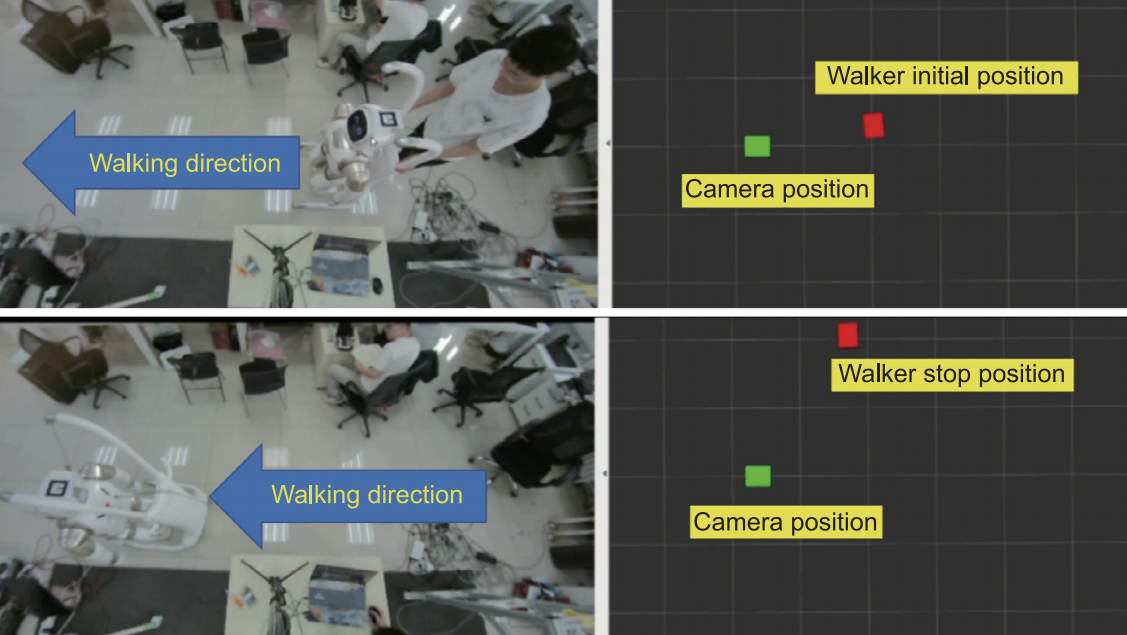
Ma, H., Song, A., Li, J., Zhang, G., et al.
Legged Odometry Based on Fusion of Leg Kinematics and IMU Information in a Humanoid Robot.
Biomimetic Intelligence and Robotics, 2025. Accepted.
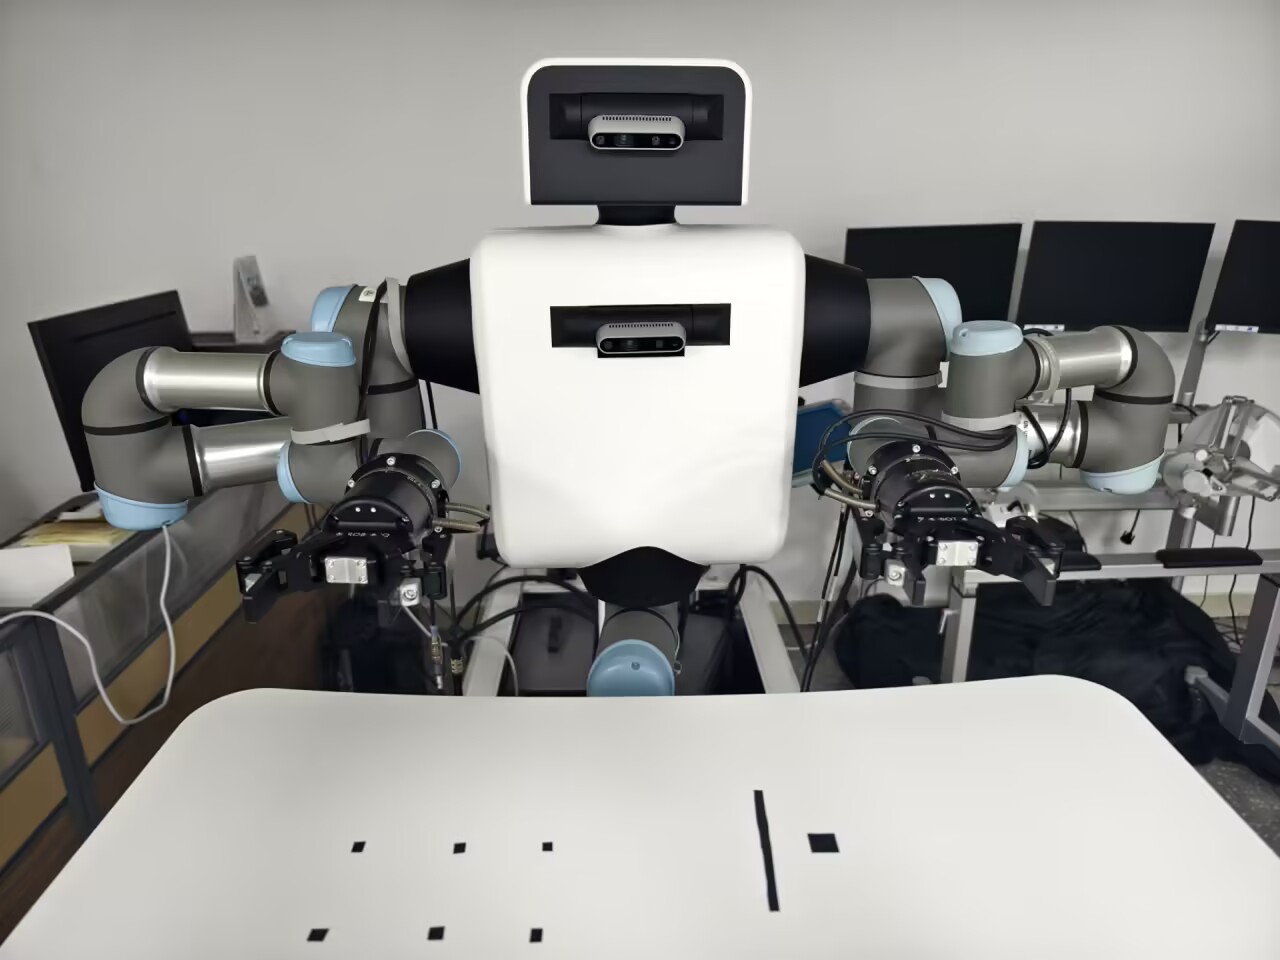
He, M., Song, A., Yan, Y., Ma, H., et al.
A Multimodal Shared Telerobotic System of Three-arm Space Robot for Extravehicular Activities.
Proceedings of the 23rd IFAC Symposium on Automatic Control in Aerospace (ACA 2025), Harbin, China, 2025. Accepted.
Academic Links
Visitor Map
Contact
I welcome opportunities to discuss and collaborate on embodied intelligence, world models, VLA models, robot data generation, teleoperation, and dexterous manipulation.
Email: huailiangma@163.com